Little Things That Matter: Jerk
When you ride a subway train, and the train decelerates to its station, you feel your body pulled forward, and your muscles tense to adjust, but then when the train reaches a sudden stop, you are suddenly flung backward, since you are no longer decelerating, but your muscles take time to relax and stop fighting a braking that no longer exist. This effect is called jerk, and is defined to be change in acceleration, just as acceleration is change in speed and speed is change in position. Controlling jerk is crucial for a smooth railway ride. Unfortunately, American mainline rail is not good at this, leading to noticeable jolts by passengers even though speed limits on curves and acceleration rates are very conservative.
This is particularly important for speeding up mainline trains around New York and other legacy cities in the US, like Boston. Speeding up the slowest segments is more important than speeding up the fastest ones; my schedules for New York-New Haven trains, cutting trip times from 2:09 to 1:24, save 4 minutes between Grand Central and 59th Street just through avoiding slowdowns in the interlocking. The interlocking is slow because the switches have very conservative speed limits relative to curve radius (that is, lateral acceleration), which in turn is because they are not designed with good lateral jerk control. The good news is that replacing the necessary infrastructure is not so onerous, provided the railroads know what they need to do and avoid running heavy diesel locomotives on delicate infrastructure.
Spirals and jerk
In practice, the worst jerk is usually not forward or backward, except in the last fraction of a second at the end of acceleration. This is because it takes about a second for train motors to rev up, which controls jerk during acceleration. Rather, the worst is sideways, because it is possible to design curves that transition abruptly from straight track, on which there is no lateral acceleration, to curved track, on which there is, in the form of centrifugal force centripetal force.
To reduce jerk, the transition from straight track to a circular arc is done gradually. There are a number of usable transition curve (see Romain Bosquet’s thesis, PDF-p. 36), but the most common by far is called the clothoid, which has the property of having constant change in curvature per unit of arc length – that is, constant jerk. Different countries have different standards for how long the clothoid should be, that is what the maximum lateral jerk is. Per Martin Lindahl’s thesis, the limit in Sweden is 55 mm/s (PDF-p. 30) and that in Germany is 69.44 mm/s (PDF-p. 38), both measured in units of cant deficiency; in SI units, this is 0.367 m/s^3 and 0.463 m/s^3 respectively. In France, the regular limit is 50 mm/s (Bosquet’s thesis, PDF-p. 35), that is 0.333 m/s^2, but it is specifically waived in turnouts.
Track switches are somehow accepted as sites of very high jerk. A presentation about various technical limits in France notes on p. 106 that in switches (“appareils de voie” or “aiguilles” or “aiguillages,” depending on source, just like “switch” vs. “turnout” in English), the jerk can be increased to 100 and even 125 mm/s. On p. 107 it even asserts that in exceptional circumstances, abrupt change in cant deficiency of up to 50 mm on main track and 100 on the diverging direction on a switch is allowed; see also PDF-pp. 13-15 of a pan-European presentation. Abrupt changes are not good for passengers, but will not derail a train.
Turnout design in the advanced world
Second derivative control, that is acceleration and cant deficiency, can be done using calculus and trigonometry tools. Third derivative control, that is clothoids and jerk, requires numerical calculations, but fortunately they are approximated well by pretending the clothoid is half straight line, half circular arc, with the length determined by the maximum jerk. Working from first principles, it’s possible to figure out that at typical turnout needs – e.g. move a train from one track to a parallel track 4 meters away – the clothoid is far longer than the curve itself, and at 50 mm/s jerk and 150 mm cant deficiency it’s not even possible to hit a curve radius of 250 meters.
Turnouts are inherently compromises. The question is just where to compromise. Here, for example, is a French turnout design, in two forms: 0.11 and 0.085. The numbers denoting the tangent of the angle at the frog, and the radius is proportional to the inverse square of the number, thus the speed is proportional to the inverse of the number. The sharper turnout, the 0.11, has a radius of 281 meters, a maximum speed of 50 km/h, and a total length of 26 meters from point to frog (“lead” in US usage), of which the clothoid curve (“point”) takes up 11, to limit jerk to 125 mm/s at a cant deficiency of 100 mm. The 0.085 turnout has a radius of 485 meters, a maximum speed of 65 km/h, a lead of about 38 meters, and a point of about 14.5 meters.
In Germany, turnouts have somewhat independent numbers and radii – some have shorter leads than others. The numbers are the inverse of those of France, so what France calls 0.11, Germany calls 1:9, but at the end of the day, the curve radius is the important part, with a cant deficiency of 100 mm. A higher cant deficiency may be desirable, but lengthening the point requires almost as much space as just increasing the curve radius, so might as well stick with the more comfortable limits.
Turnout design in the United States
American turnouts look similar to French or German ones, at first glance. I’ve seen a number of different designs; here’s one by CSX, on PDF-pp. 22 (#8) and 24 (#10), the numbers being very roughly comparable to German ones and inverses of French ones. CSX’s #10 has a curve radius of 779.39′, or 238 meters, and a lead of 24 meters, both numbers slightly tighter than the French 0.11. The radius is proportional to the square of the number, and so speed is proportional to the number.
However, the cant deficiency is just 50 mm. The point is not always curved; Amtrak’s low-number switches are not, so the change in cant deficiency is abrupt. Judging by what I experience every time I take a train between New York and New Haven, Metro-North’s switches have abrupt change in cant deficiency even on the mainline. The recommended standards by AREMA involve a curved point, but the point is still much shorter than in France (19.5′, or just under 6 meters, on a #12), so a 125 mm/s jerk only gets one up to about 62 mm cant deficiency.
The reason for this is that European turnouts are curved through the frog, whereas American ones are always straight at the frog. Extremely heavy American freight trains do not interact well with curved frogs and long points.
One might ask, why bother with such turnout design on rail segments that never see a heavy freight locomotive or 130-ton freight car? And on segments that do see the odd freight locomotive, like the approaches to Grand Central and Penn Station with the rare dual-mode locomotive, why not kick out anything that doesn’t interact well with advanced track design? Making a handful of passengers transfer would save around 4 minutes of trip time on the last mile into Grand Central alone for everyone else, not to mention time savings farther up the line.

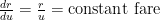
 , we get

 , we get


